
More project photos (3)
The problem
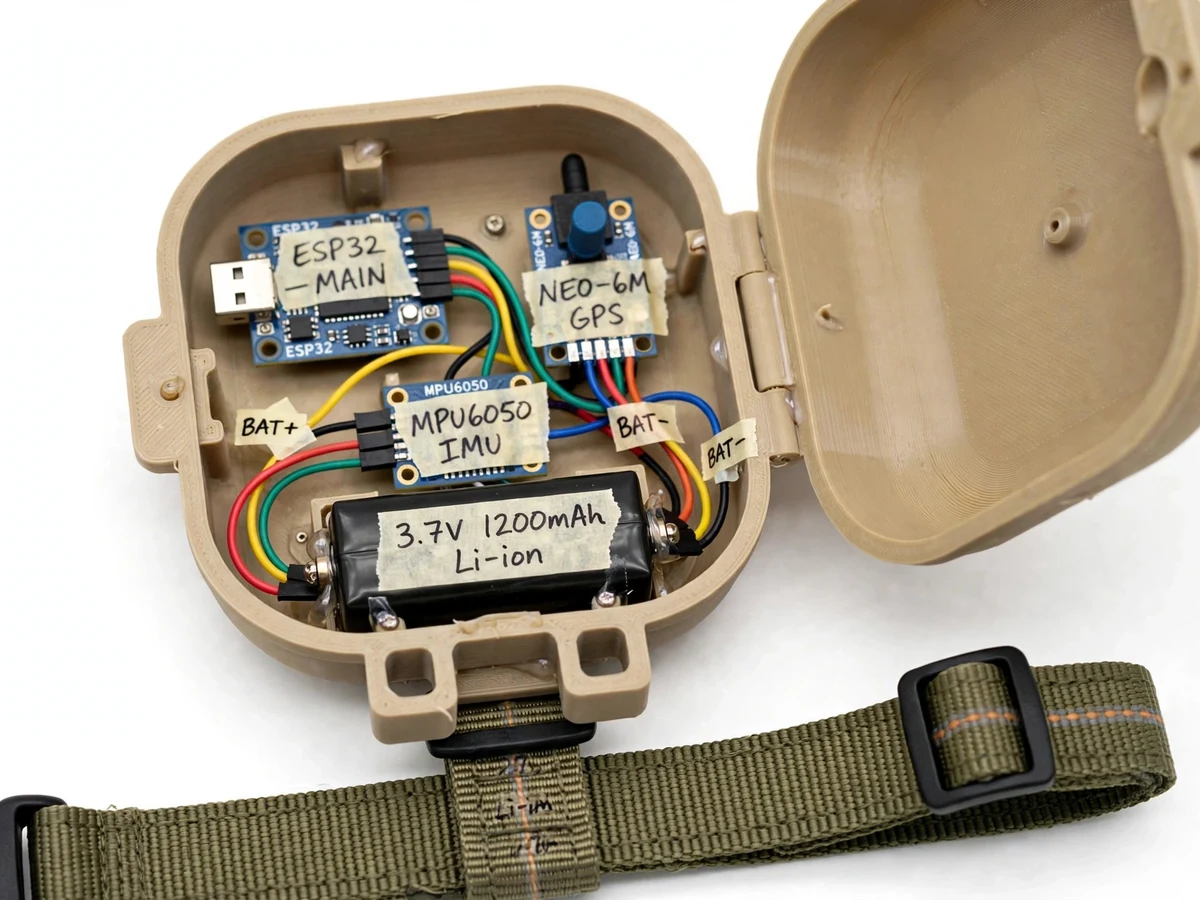
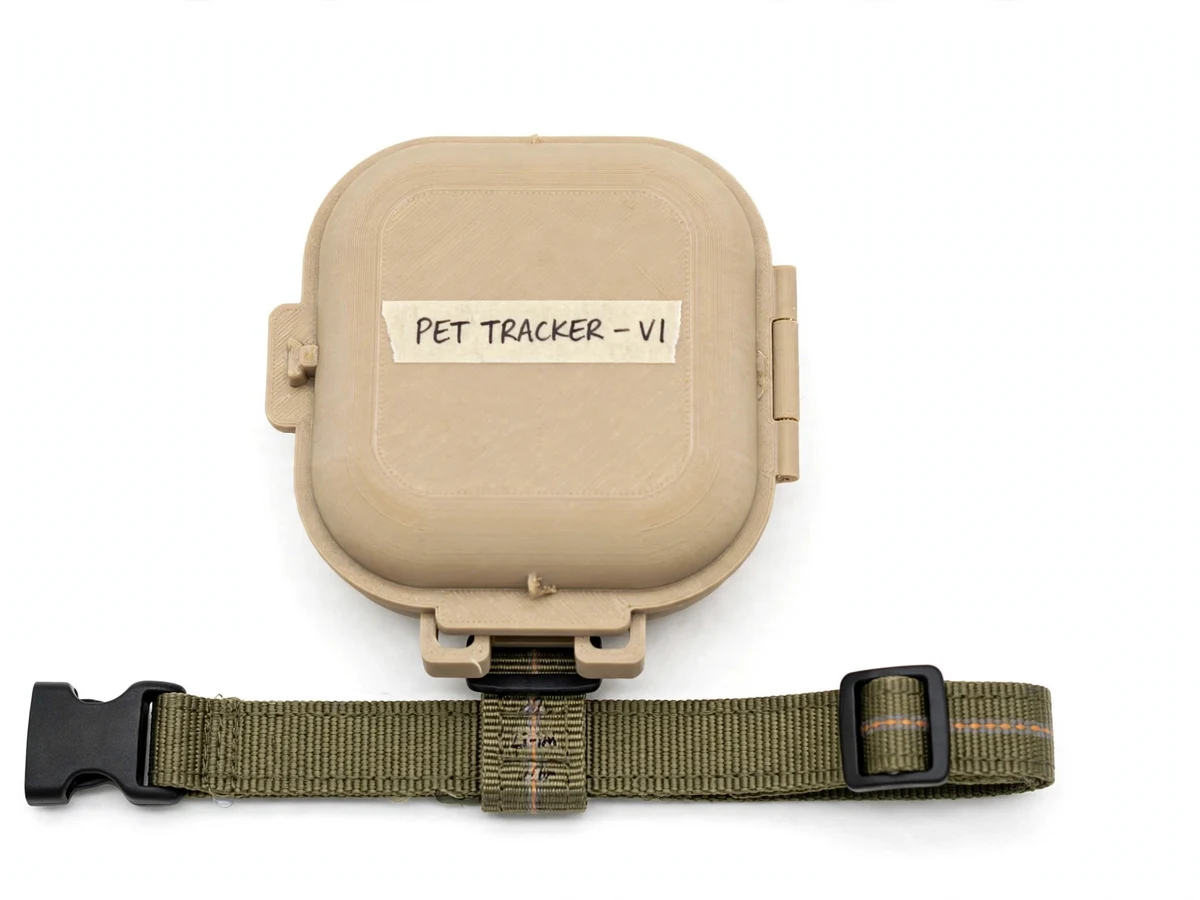
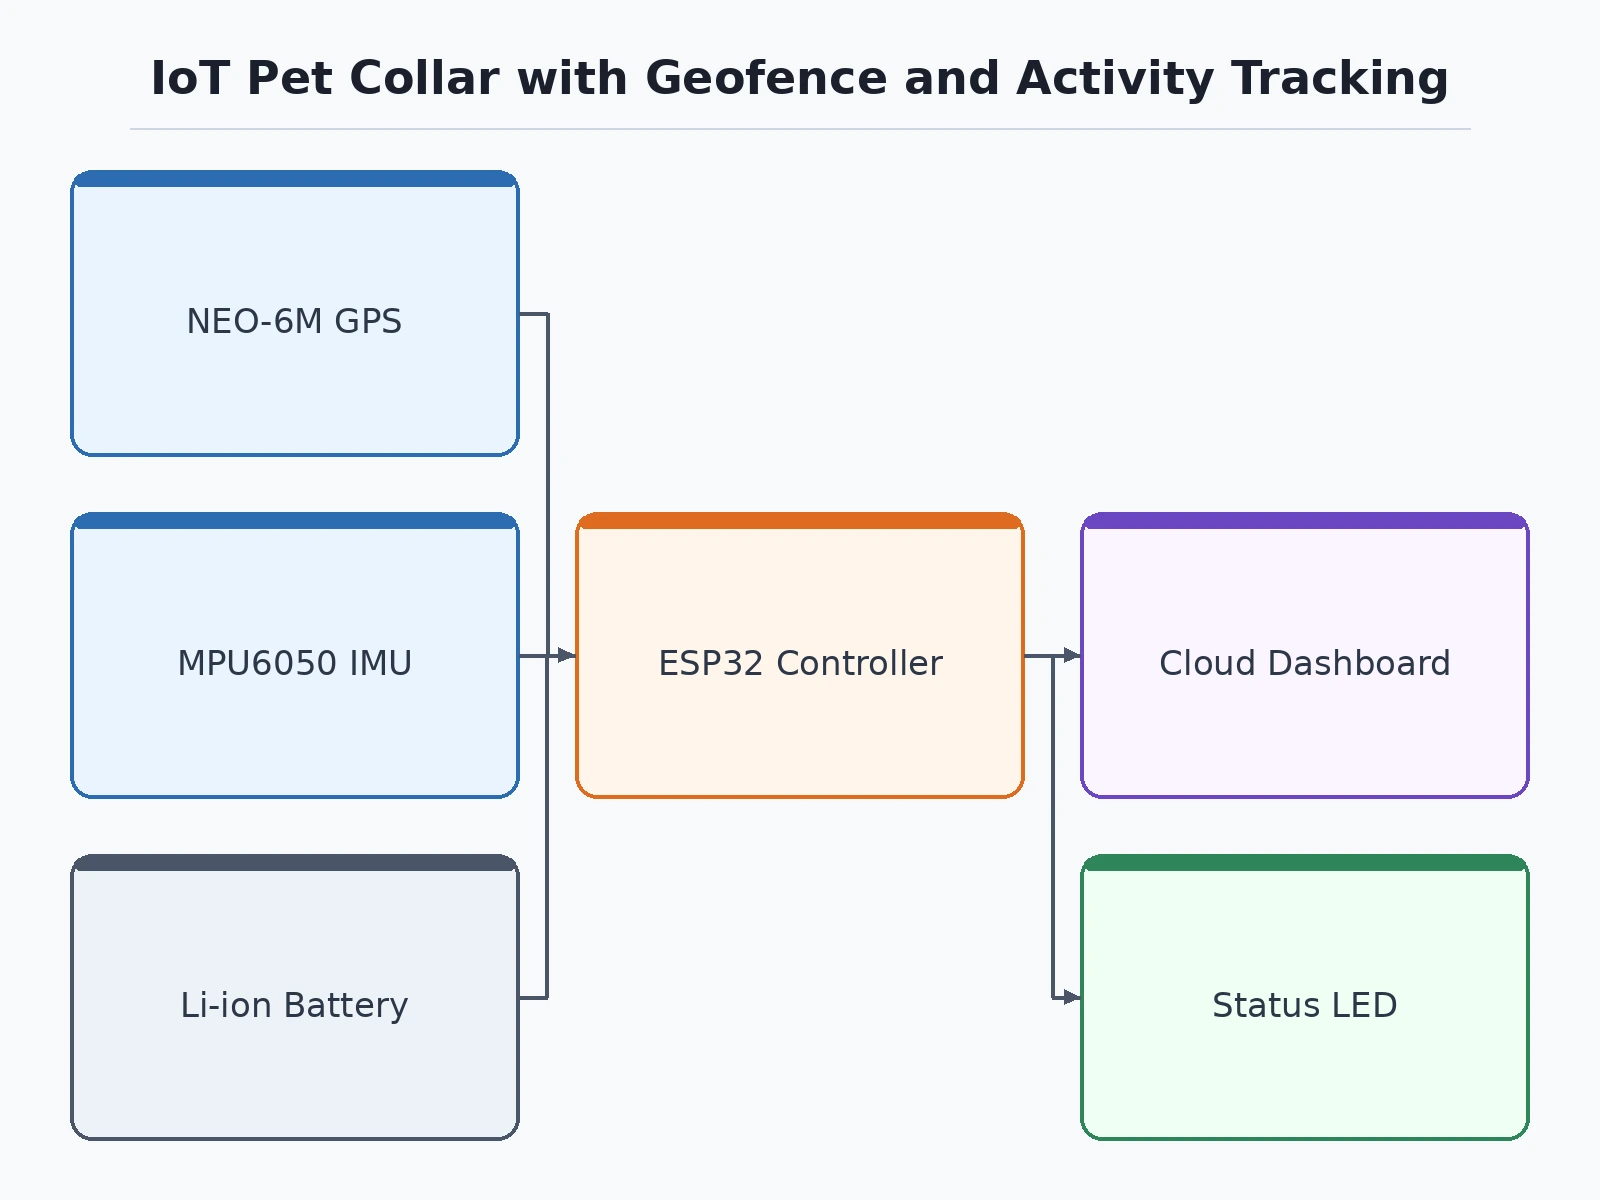
Pets slip out of gates and go missing every day, and owners discover it hours later when someone notices the empty yard. Commercial GPS pet trackers exist but charge subscriptions and hide their workings. This project builds an open pet collar on an ESP32: a NEO-6M GPS module for position, an MPU6050 IMU that classifies rest versus activity, and firmware that defines a home geofence — crossing it raises an immediate alert on the owner's phone dashboard, which also shows the track history and a daily activity summary. The collar is a genuine wearable design problem: weight, battery life and a pet-safe enclosure all constrain the build, and the report documents those trade-offs honestly. GPS accuracy is the NEO-6M's rated outdoor performance, stated as a datasheet value, not a measured claim.
Acquires the position fix outdoors so the collar can publish live location.
Follow the working sequence
How it works
- The GPS, IMU and ESP32 are assembled in the lightweight enclosure and fitted to a standard collar strap.
- The owner sets the home coordinates and geofence radius in the firmware configuration.
- On power-up the collar acquires a GPS fix (outdoors) and starts publishing position and activity over Wi-Fi.
- The IMU continuously classifies rest versus movement; the firmware accumulates active minutes.
- Crossing the geofence boundary triggers an immediate alert on the dashboard; the track history records the excursion.
- The dashboard renders the live position, track history and daily activity summary for the owner.
Tech stack:
- ESP32 development board (Wi-Fi)
- NEO-6M GPS module
- MPU6050 IMU
- Li-ion battery + charging module
- 3D-printed pet-safe enclosure
- Blynk / ThingSpeak class dashboard
- Status LED
- Arduino IDE (C/C++ firmware)
| Parameter | Value |
|---|---|
| GPS | NEO-6M, approximately ±2.5 m accuracy outdoors (datasheet) |
| IMU | MPU6050 6-axis, rest/activity classification |
| Geofence | Configurable radius around home coordinates |
| Battery | Li-ion; life depends on fix rate (design target: a full day) |
| Weight budget | Enclosure + electronics target under ~80 g (design) |
| Connectivity | Wi-Fi 2.4 GHz; tracking works within home-network range |
| Enclosure | 3D-printed, rounded, collar-strap mount |
| Alerts | Geofence breach + low battery on dashboard |
Project features
- [GPS geofence alerts] A configurable home radius around the house; the collar raises an immediate dashboard alert when the pet crosses the boundary.
- [Live location tracking] GPS fixes are published over Wi-Fi to the dashboard with a track history of where the pet has been.
- [IMU activity classification] An MPU6050 distinguishes rest from movement, building a daily activity summary (active minutes vs rest).
- [Daily activity summary] The dashboard aggregates active time per day so owners can spot lethargy trends worth a vet visit.
- [Low-battery alert] Battery voltage is monitored and a low-battery alert is raised before the collar goes dark.
- [Pet-safe wearable enclosure] A lightweight 3D-printed enclosure with rounded edges and a standard collar strap mount, documented with a weight budget.
- [On-collar status LED] A small LED signals GPS fix and alert states without needing the phone.
What is included
- ESP32 collar electronics with GPS and IMU in a pet-safe enclosure
- Collar strap mount and weight-budget documentation
- ESP32 firmware (GPS, geofence logic, activity classification, dashboard)
- Enclosure 3D-print files and assembly guide
- Project report PDF, PPT presentation and viva Q&A document
Limitations & prerequisites
- GPS needs open sky — indoors or under dense cover, fixes degrade or drop; the dashboard shows last-known position honestly.
- Tracking range is limited to Wi-Fi coverage; this is a home-and-neighbourhood tracker, not a cellular one (cellular variant is future scope).
- ±2.5 m GPS accuracy is the module's datasheet rating outdoors, not a measured claim.
- Battery life depends on the GPS fix rate; continuous tracking trades against the design target of a full day.
- Activity classification is rest-vs-active only — not a veterinary diagnostic.
Frequently Asked Questions
How does the geofence alert work?
The owner configures home coordinates and a radius. The collar checks each GPS fix against the boundary and publishes an immediate alert to the dashboard when the pet crosses it.
How accurate is the location?
The NEO-6M is rated at approximately ±2.5 m outdoors (datasheet). Indoors or under dense tree cover, accuracy degrades and the dashboard shows the last-known fix.
What is the tracking range?
Wi-Fi range — this is a home-and-neighbourhood tracker with no subscription. A cellular (4G) variant for unlimited range is listed as future scope.
How does it track activity?
The MPU6050 IMU classifies rest versus movement; the firmware accumulates active minutes and the dashboard shows a daily summary, useful for spotting lethargy trends.
Is the collar safe and comfortable?
The enclosure is 3D-printed with rounded edges, mounts on a standard collar strap, and the design targets under ~80 g total. The weight budget is documented in the report.
Is this project suitable for a final-year project?
Yes — for IoT & Embedded and Electronics programs. It combines GPS, IMU sensing, geofence logic, wearable power budgeting and a mobile dashboard. Suitable for B.E./B.Tech final-year projects in IoT & Embedded Systems and Electronics.
Components & software requirements
- ESP32 development board (Wi-Fi)
- NEO-6M GPS module
- MPU6050 IMU
- Li-ion battery + charging module
- 3D-printed pet-safe enclosure
- Blynk / ThingSpeak class dashboard
- Status LED
- Arduino IDE (C/C++ firmware)
Delivery information
Built-to-order project. Delivery timeline is shared after order confirmation based on current queue.
Support terms
Complete documentation, setup guide, and viva preparation included. Support for setup and explanation provided.
Download free synopsis (PDF)
Enter your name and WhatsApp number — the synopsis PDF downloads immediately. We may send occasional project updates on WhatsApp; no spam.